Components
103 components built on the tokens, by group: actions and inputs every product needs, then the robotics components and the robot shell, then data, charts, media, feedback, navigation, overlays and layout.
Actions7
Inputs26
Robotics8
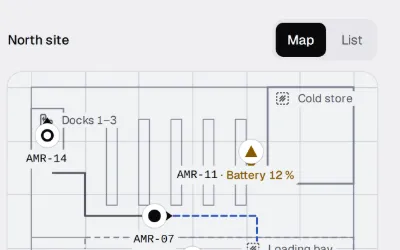
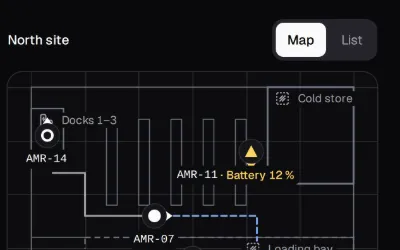
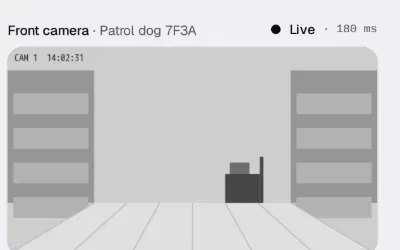
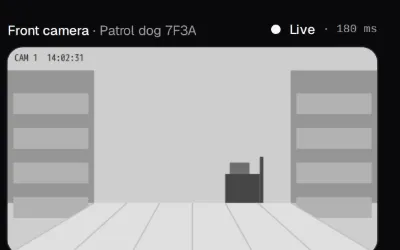
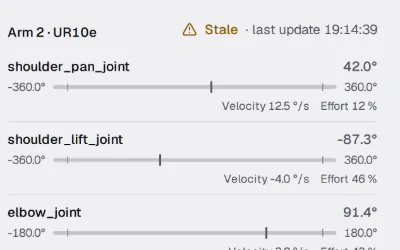
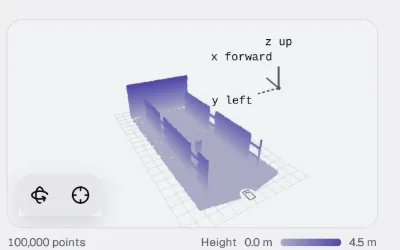
Robot shell3
Data display19
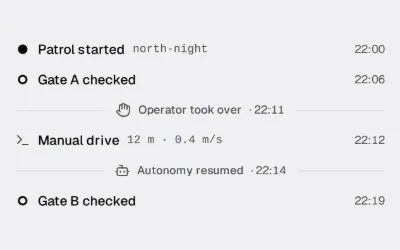
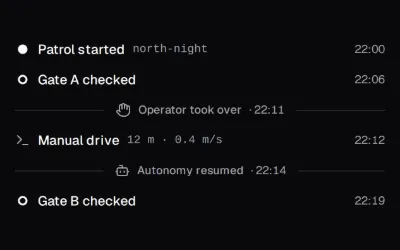
Charts2
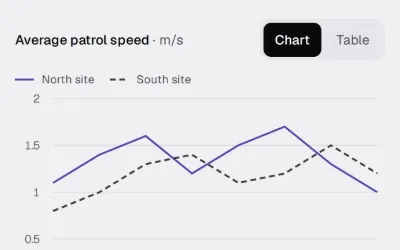
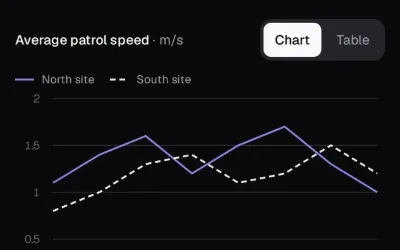
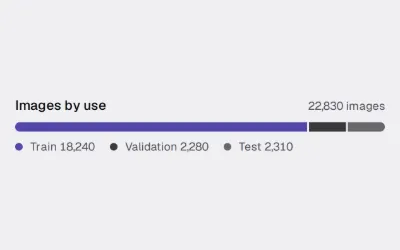
Media & files6
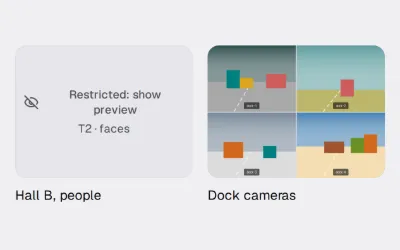
Feedback9
Navigation9
Overlays9
Layout5
Hooks & libraries7
- ROSROS and ROS 2 over rosbridge with no ROS library: a rosbridge v2 client on the browser's WebSocket (ref-counted subscriptions and advertisements, capped jittered reconnect that resubscribes, a send queue, service calls with a timeout, a zero Twist when a velocity publisher stops or the link drops) and pure converters from OccupancyGrid, LaserScan, PointCloud2, JointState and poses to the kit's components, and from a teleop command and a map goal back to Twist and PoseStamped.
- useLongPressPress and hold with progress from 0 to 1.
- useSlideReleaseDrag, threshold and spring-back logic for slide to release.
- usePresenceKeeps an element, or list items, on screen while they leave, so exits use the disappear movement instead of vanishing.
- useDebounceA value, or a function call, that waits until changes pause: a search sent when the typing stops, not on every key.
- useRosReact hooks over the ros client: RosProvider, useRosStatus, useRosTopic (the latest message, through useSyncExternalStore), useRosPublisher (a stable publish function; a zero Twist on unmount, hidden page and dropped link for cmd_vel) and useRosService (a call with a timeout).
- useHotkeysKeyboard shortcuts as a map of keys to handlers ({ "1": yes, "mod+z": undo, "?": help }), quiet while someone types in a field, with the key being pressed for Kbd.